


UNITREE D1 robotic arm
 Drone service
 Rental
 Reliability
 Trust
 Own warehouse
 Warranty

UNITREE D1 Robotic Arm
The UNITREE D1 Robotic Arm is a versatile robotic manipulator designed for object handling and human hand motion imitation. It is a great fit for R&D environments, test benches, teleoperation systems, and hands-on robotics projects where precise gripper control in 3D space matters. Whether you want to grab, move, position, or demonstrate object manipulation, the D1 offers a practical and engaging platform for hobbyist and experimental use.
- Designed for object manipulation and motion replication
- Great for robotics experiments, teleoperation, and test setups
- Supports precise gripper positioning in multiple orientations
- Wide joint motion ranges for complex movement paths
- Suitable for research, demonstrations, and advanced hobby projects
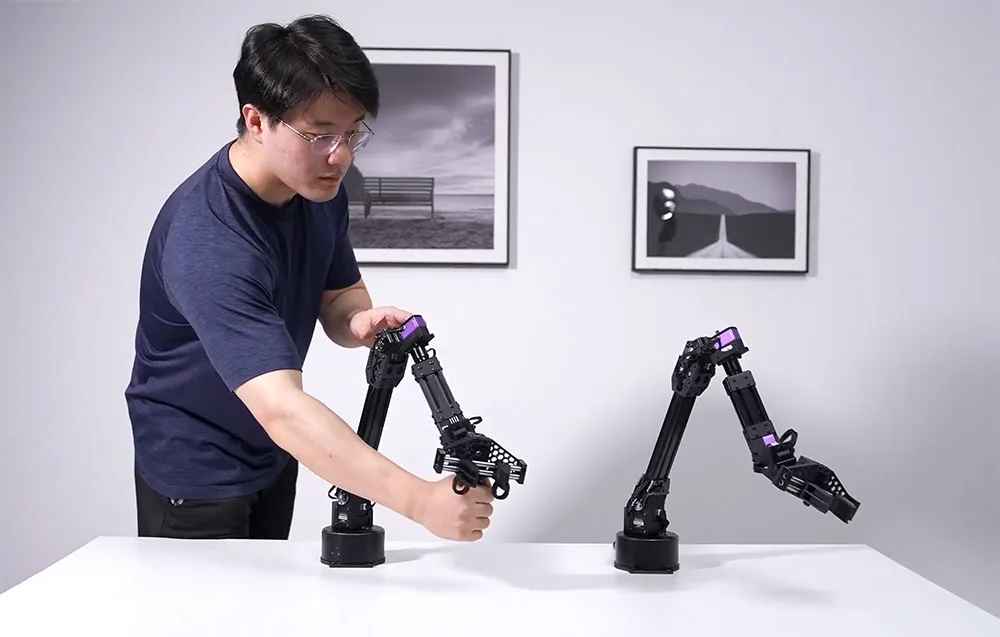
Built for Advanced Manipulation Tasks
The D1 Robotic Arm features a multi-joint rotary design responsible for base movement, arm articulation, and wrist section control. This configuration allows the end effector to be positioned freely in a variety of orientations, making the arm an excellent choice for exploring coordination, manipulation accuracy, and motion synchronization in robotic systems.
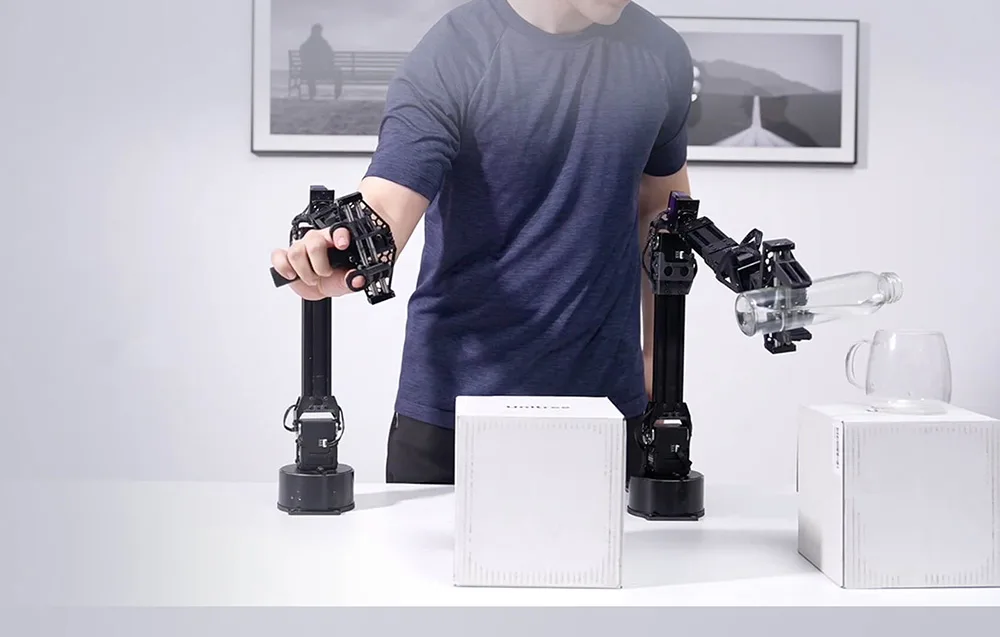
Wide Range of Motion
Thanks to its broad joint rotation ranges, the UNITREE D1 can perform complex motion trajectories and operate in multiple working configurations. This makes it ideal for experiments involving objects of different shapes and positions, as well as for practical demonstrations of how robotic arms work in real-world scenarios.
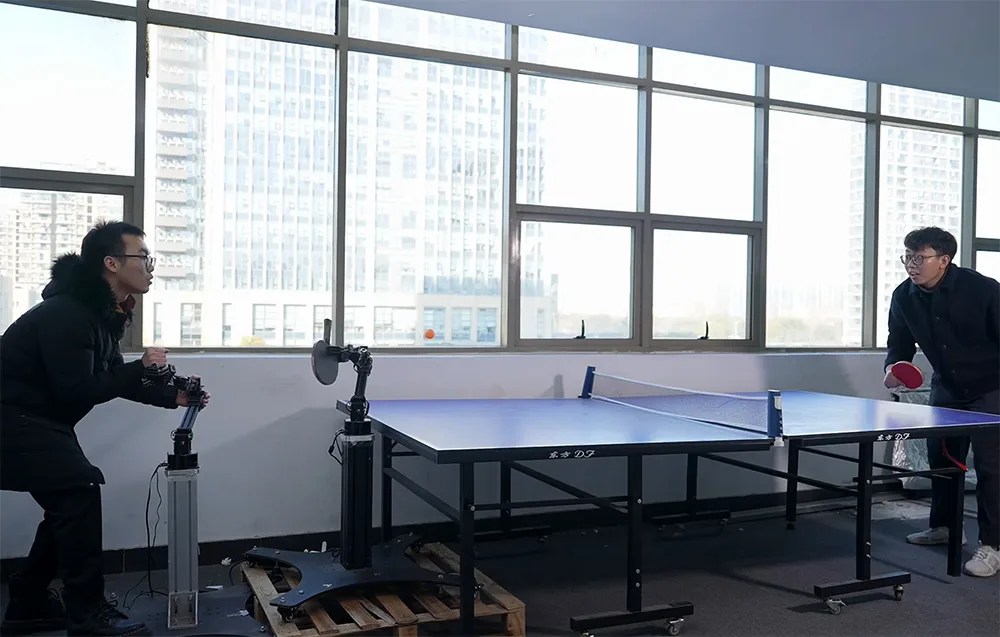
Technical Specifications
| Brand | Unitree |
|---|---|
| Model | D1 |
| Joint 0 Range of Motion | ±135° |
| Joint 1 Range of Motion | ±90° |
| Joint 2 Range of Motion | ±90° |
| Joint 3 Range of Motion | ±135° |
| Joint 4 Range of Motion | ±90° |
| Joint 5 Range of Motion | ±135° |
| Joint 6 Range of Motion | From −40° to 20° |
Specification UNITREE D1 robotic arm
 Get expert advice